Vinod Anbalagan
ML engineer and independent researcher · world models and robot learning · Toronto
I’m interested in world models as the basis for robot control, and especially in memory: what a planning agent needs to remember, and how to keep that memory small enough to plan in real time.
More broadly, I want to work on world models that adapt, where agents organise and refine what they keep as tasks and environments change.
Right now I am building Notch: what should a robot remember? It compares the signals that could decide what a world-model planner writes into a small, fixed memory, including a new one: whether an observation changed the plan. Reliability and planning speed are measured together, on tasks that cannot be solved from the current camera frame.
One candidate signal, sketched: surprise. Most moments are predictable, so nothing is stored; when the world does something the model did not predict, that moment is written to a small, fixed memory. Notch compares this rule with four others, including whether the observation changed the plan. An illustration, not model output.
Research themes
World models for robot control
Planning inside a learned model of the world, from pixels, as the basis for acting, with speed counted alongside success.
Memory for real-time planning
What a planning agent needs to remember, what should decide it, and how small that memory can stay.
World models that adapt
Agents that organise and refine what they keep as tasks and environments change.
News
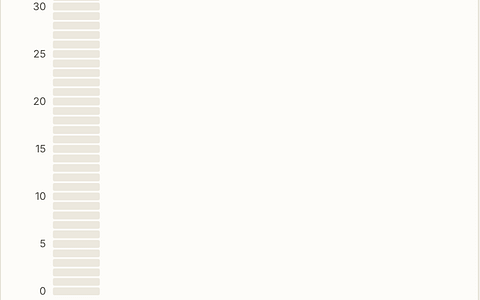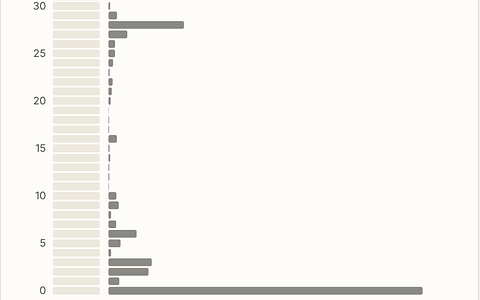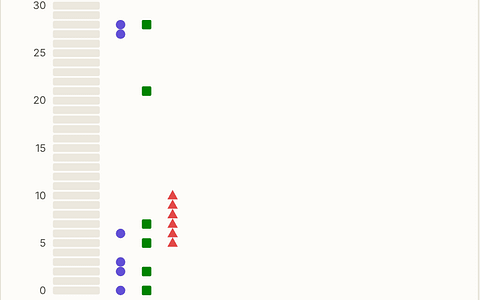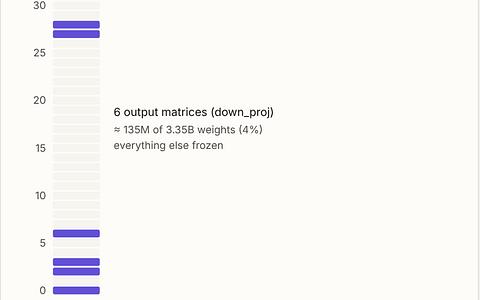
- Nov 2026New project: Where Does Forgotten Knowledge Go? Facts unlearned in English were still answered in Tamil, 34 of 34. Interactive explainer, models and every run log are public.
- Nov 2026Notch revised: it now compares five write rules for a small memory, with plan change as the new signal.
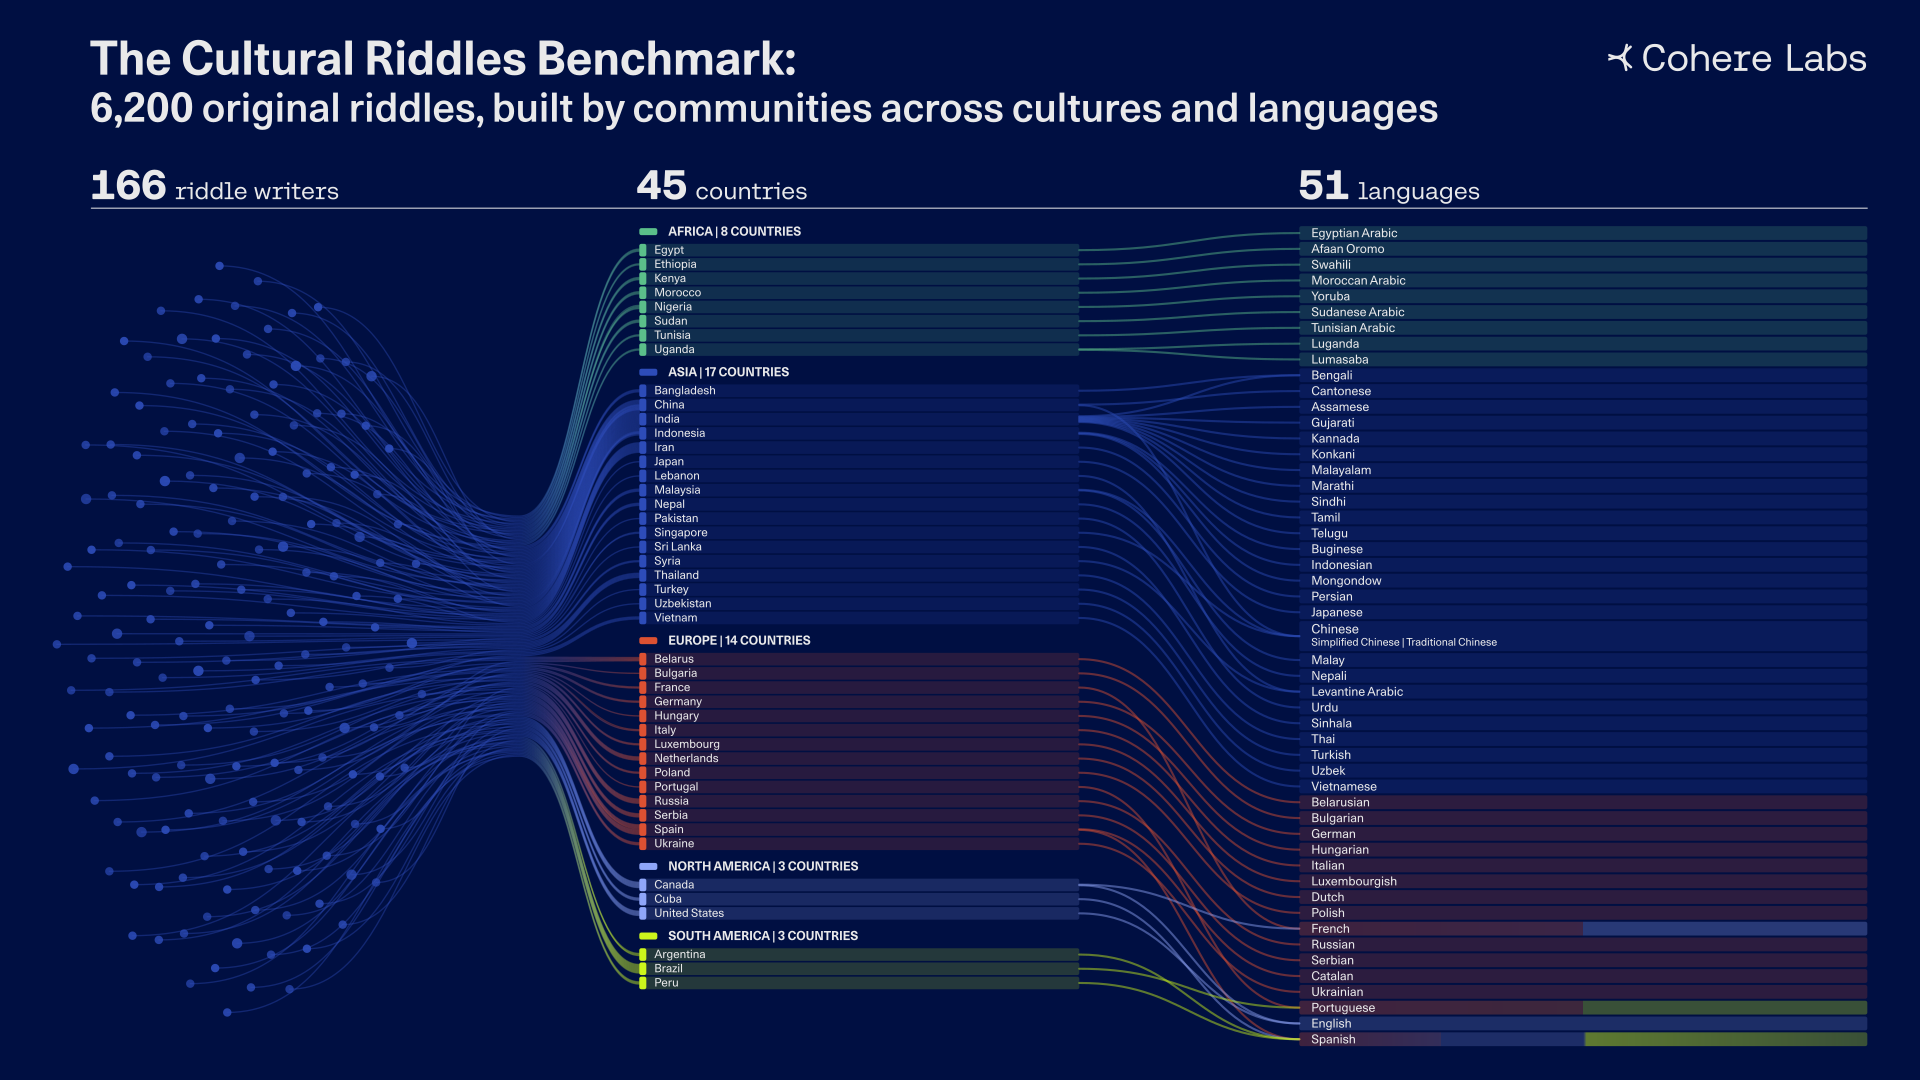
- Oct 2026CulturalRiddles is on arXiv, with a Cohere Labs research blog I co-wrote and a public results dashboard I built.
- Oct 2026Finished The Architecture of Dreams, a three-part series on world models, on The Meta Gradient.
- 20262nd place, Data and Visualization track, Adaption Labs AutoScientist Challenge.
Research
Notch
What Should a Robot Remember? Plan Change as a Write Signal for Lean Memory in World-Model Planning
In progress · preprint planned for December 2026
Where Does Forgotten Knowledge Go?
Auditing unlearning in English and Tamil: did the model really forget, or just learn to hide the answer? Facts silenced in English were still answered in Tamil, 34 of 34.
Lexsi Labs AI Safety & Alignment Hackathon · Nov 2026
CulturalRiddles
A Multicultural Benchmark of Riddles. Co-first author and cross-team lead, with the Cohere Labs Open Science Community.
arXiv preprint (Oct 2026) · MRL 2026 · under review at TACL

Writing
Where Does Forgotten Knowledge Go?
I made a model forget. Facts unlearned in English were still answered in Tamil, and the unlearned model left a trace a never-learned model does not.
The Meta Gradient · 14 Nov 2026
CulturalRiddles: Where Models Fall Short
Original riddles from 62 cultures, and what 28 language models get wrong about them: regional gaps, made-up answers, and a pull toward the familiar.
Cohere Labs research blog · co-written with Tianyi Hu, Madeline Smith and Julia Kreutzer · 22 Oct 2026
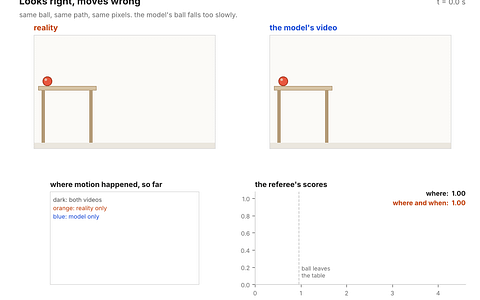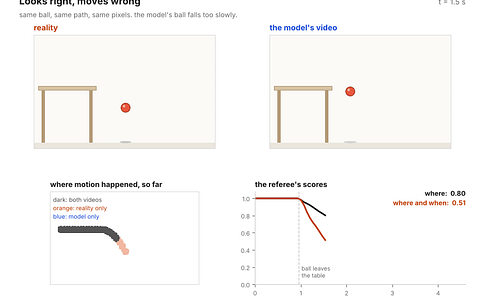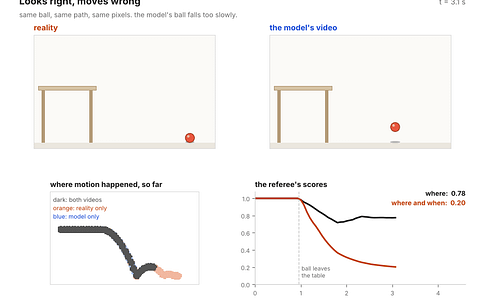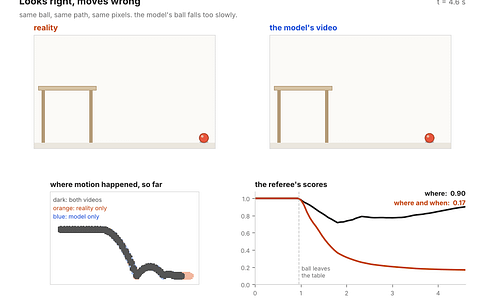
The Architecture of Dreams, Part 3: Does Looking Right Mean Understanding?
Genie, V-JEPA 2, and Physics-IQ.
The Meta Gradient · 11 Oct 2026
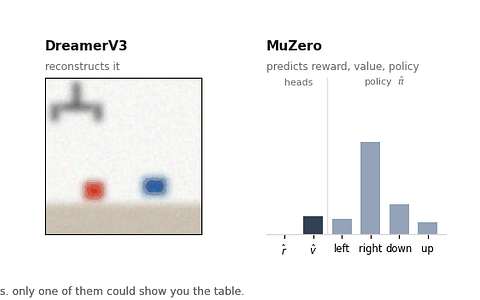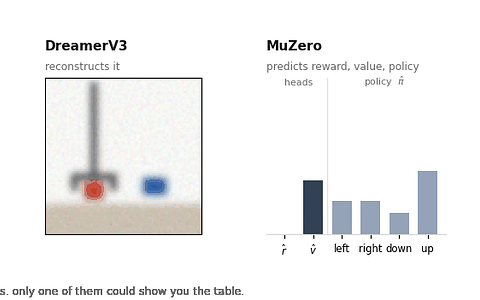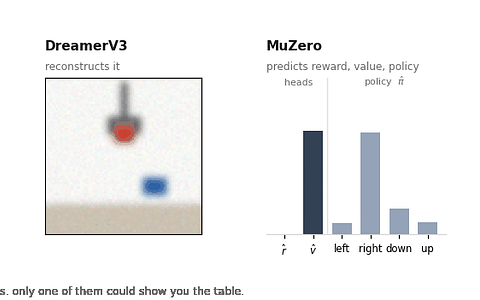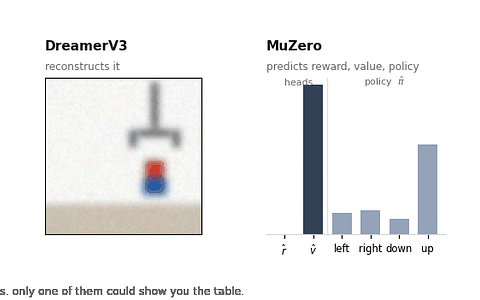
The Architecture of Dreams, Part 2: What Should a World Model Predict?
MuZero, DreamerV3, TD-MPC2.
The Meta Gradient · 28 Sept 2026
Opportunities
Open to research engineer, research assistant, and research internship opportunities, as well as funded MS/PhD positions, in world models, embodied AI and robot learning, representation learning, multimodal AI, and scientific ML.
The easiest way to reach me is email or a LinkedIn message.